The platform provides
Power, structural mounting and access to the separate flight or drive controller.
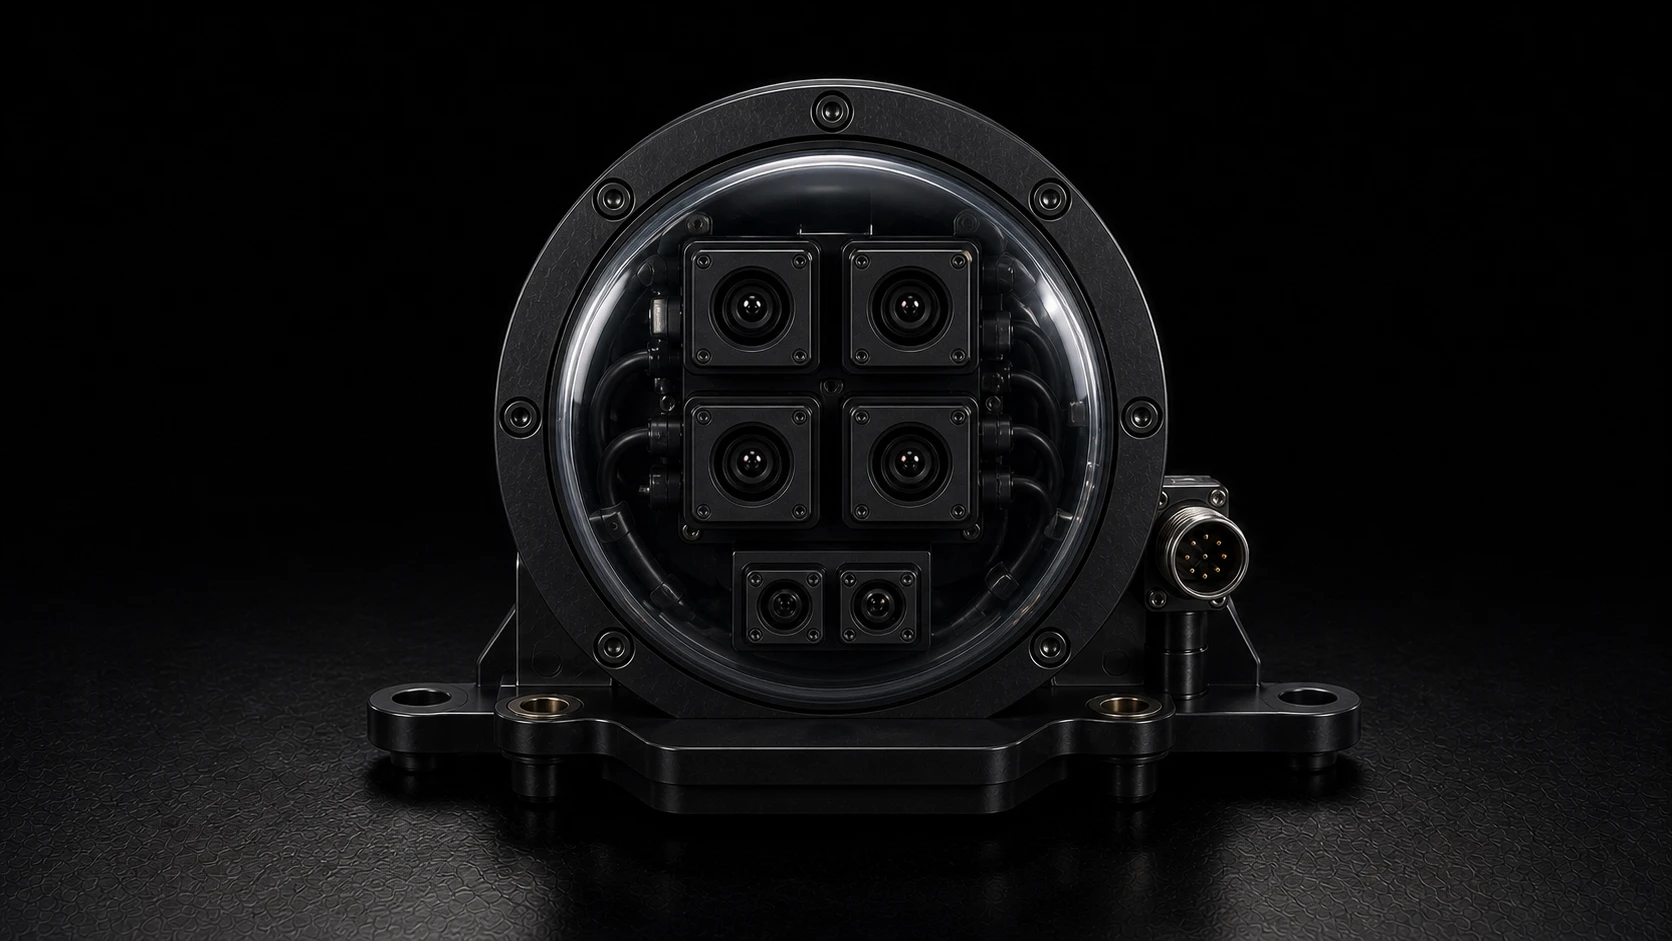
Modular perception and inference system
Multimodal AI for autonomous platforms across air, land and sea. Self-contained, configurable and built to operate without a network.
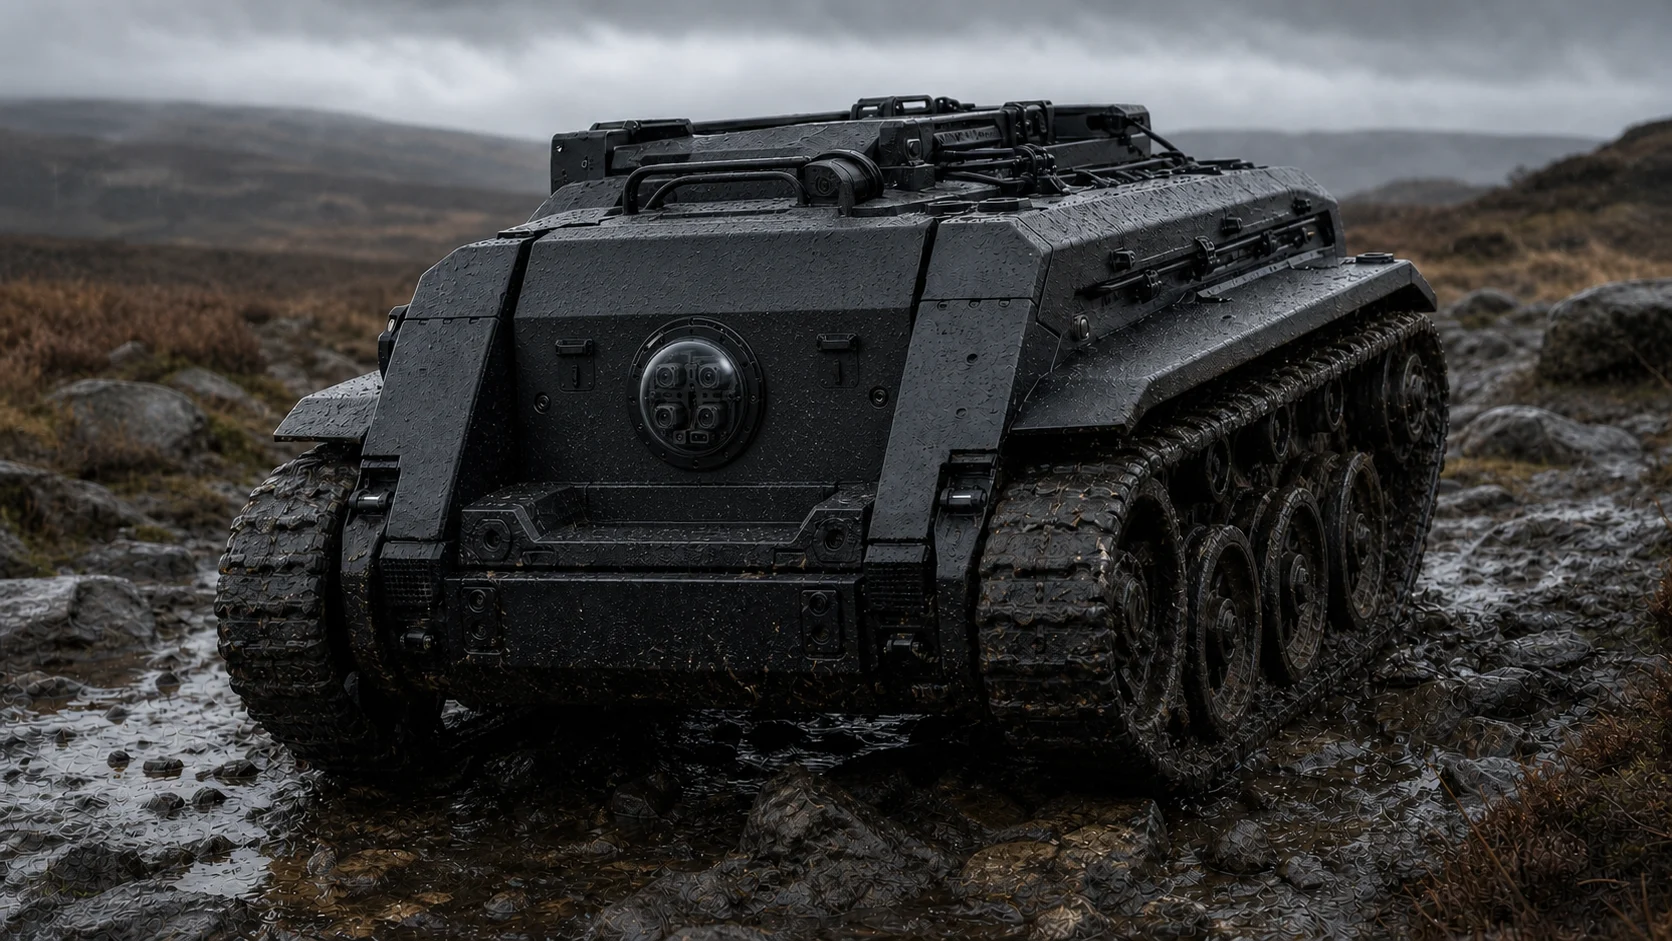
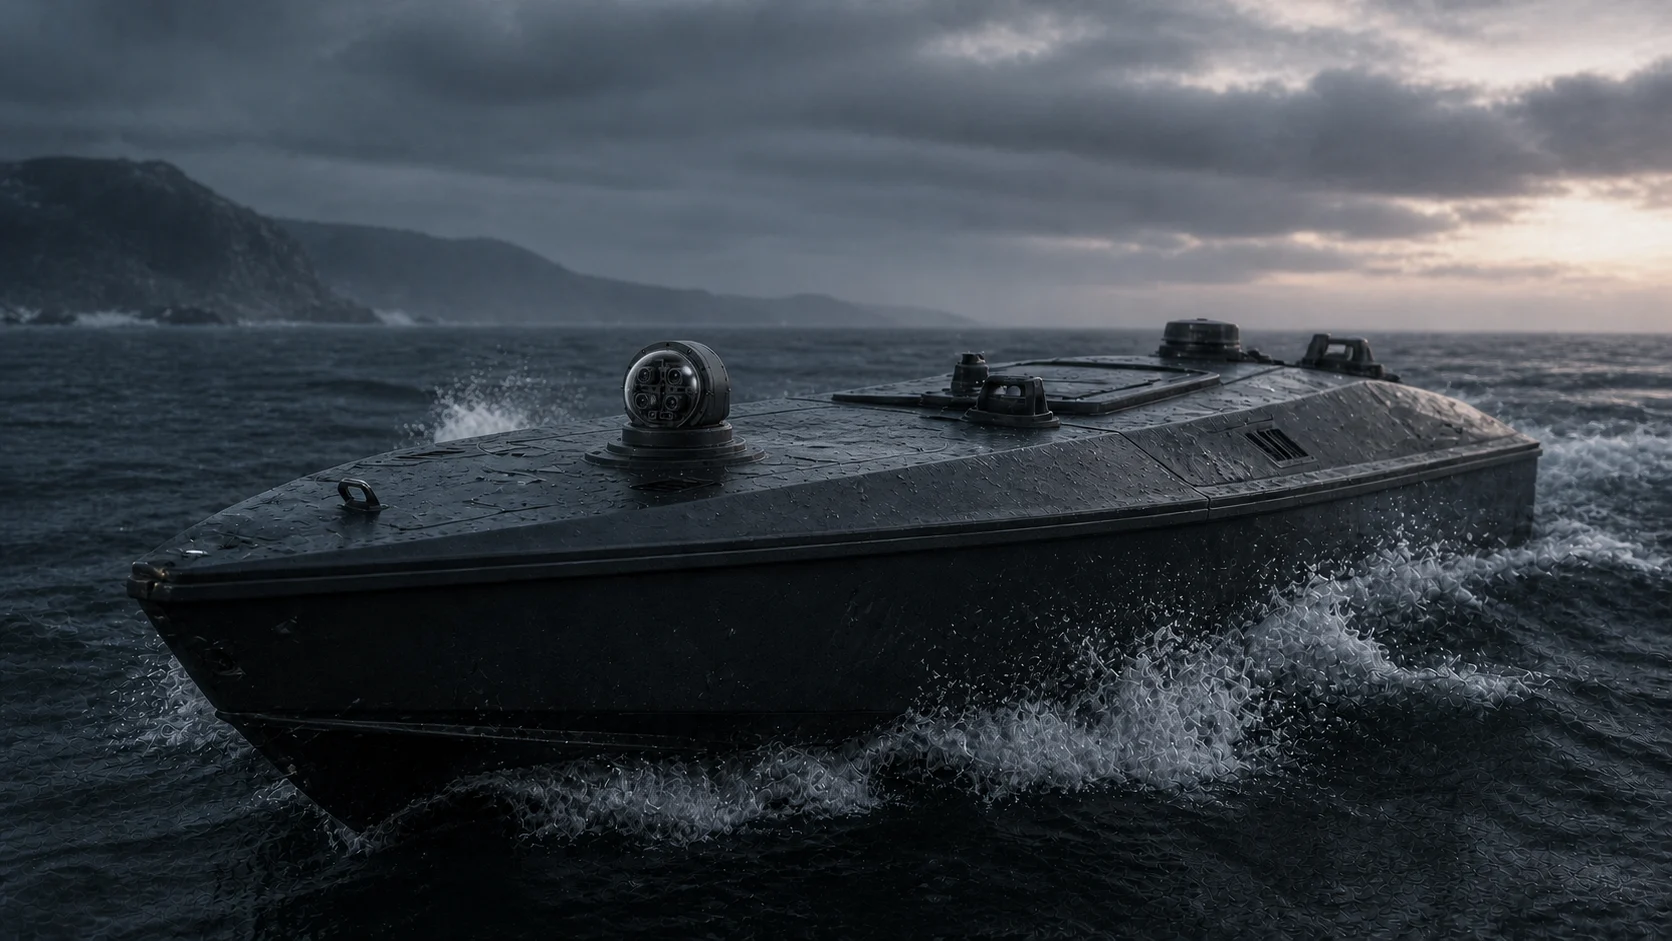
Integrate AR-01 ↗AR-01 turns a configurable set of cameras and sensors into a unified, real-time understanding of the environment. The same perception architecture moves from an aircraft to an autonomous ground vehicle or maritime platform without starting again.
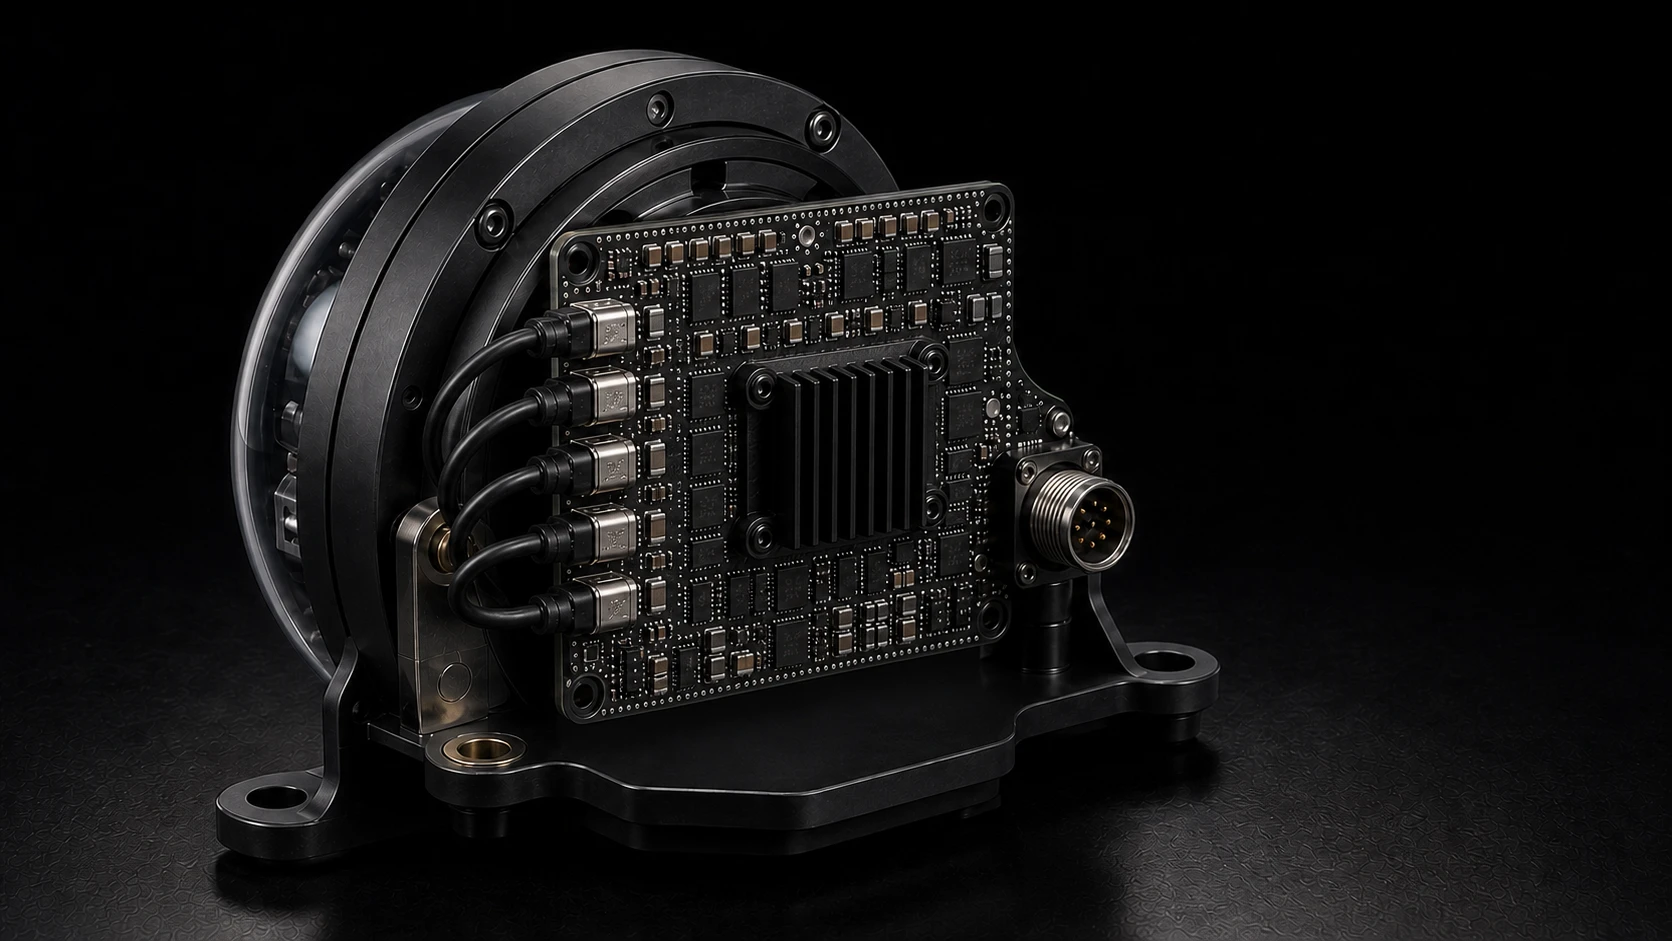
Power, structural mounting and access to the separate flight or drive controller.
Sensing, sensor fusion, inference, target acquisition, tracking, identification and autonomous decision output.
Sensor fusion and inference happen on the platform. AR-01 requires no wireless or wired uplink for navigation, identification or autonomous operation in heavily jammed environments.
Deploy a lightweight camera-led configuration or scale to five complementary modalities. The inference pipeline adapts to the sensors installed and active.
High-resolution detection and classification in clear conditions
Passive thermal awareness through darkness and low visibility
Depth, geometry, terrain mapping and obstacle clearance
All-weather ranging, motion detection and terrain awareness
Passive supplementary detection and platform health sensing
Configure up to four cameras and two auxiliary sensors around the platform's payload, power budget and operating environment instead of carrying capability the mission does not need.
Upgrade individual sensor modules as technology advances without redesigning the entire platform integration.
Multimodal inference combines complementary inputs so the platform maintains awareness when any single sensor is limited.
The result is one coherent environmental picture, produced onboard and in real time.
Continuously identify potential threats across the active sensor set.
Cross-check signatures and mission context before producing a decision output.
Maintain awareness across multiple modalities when visibility or individual sensors degrade.
Support autonomous movement through disconnected and GNSS-denied environments.
A common perception architecture for autonomous systems across every operational domain.
Talk to integration ↗